Zhuoran Li

Zhuoran Li

Hi, I’m Zhuoran (Ran). I’m an MSCS student at Stanford University. I received my B.Sc. in Data Science and Analytics with Highest Distinction from the National University of Singapore.

I am broadly interested in robot learning, planning, and agentic robotics. My goal is to build general-purpose robots that can carry out complex, long-horizon tasks and adapt their plans when conditions change. I’d like these robots to take on work ranging from routine household chores to hazardous jobs on the factory floor. I favor simple methods that scale with data and compute.

Previously, I was a research assistant working with Prof. Jiajun Wu, Prof. David Hsu, and Prof. Weiyu Liu on how large language models and vision-language models can reason and plan with abstract world models learned from unlabelled human videos. During my undergraduate studies, I worked with Prof. Jiajun Wu and Prof. Yunzhu Li on dynamic 3D scene representations for robotic manipulation.

News

Publications

* Equal Contribution   ·   † Equal Advising

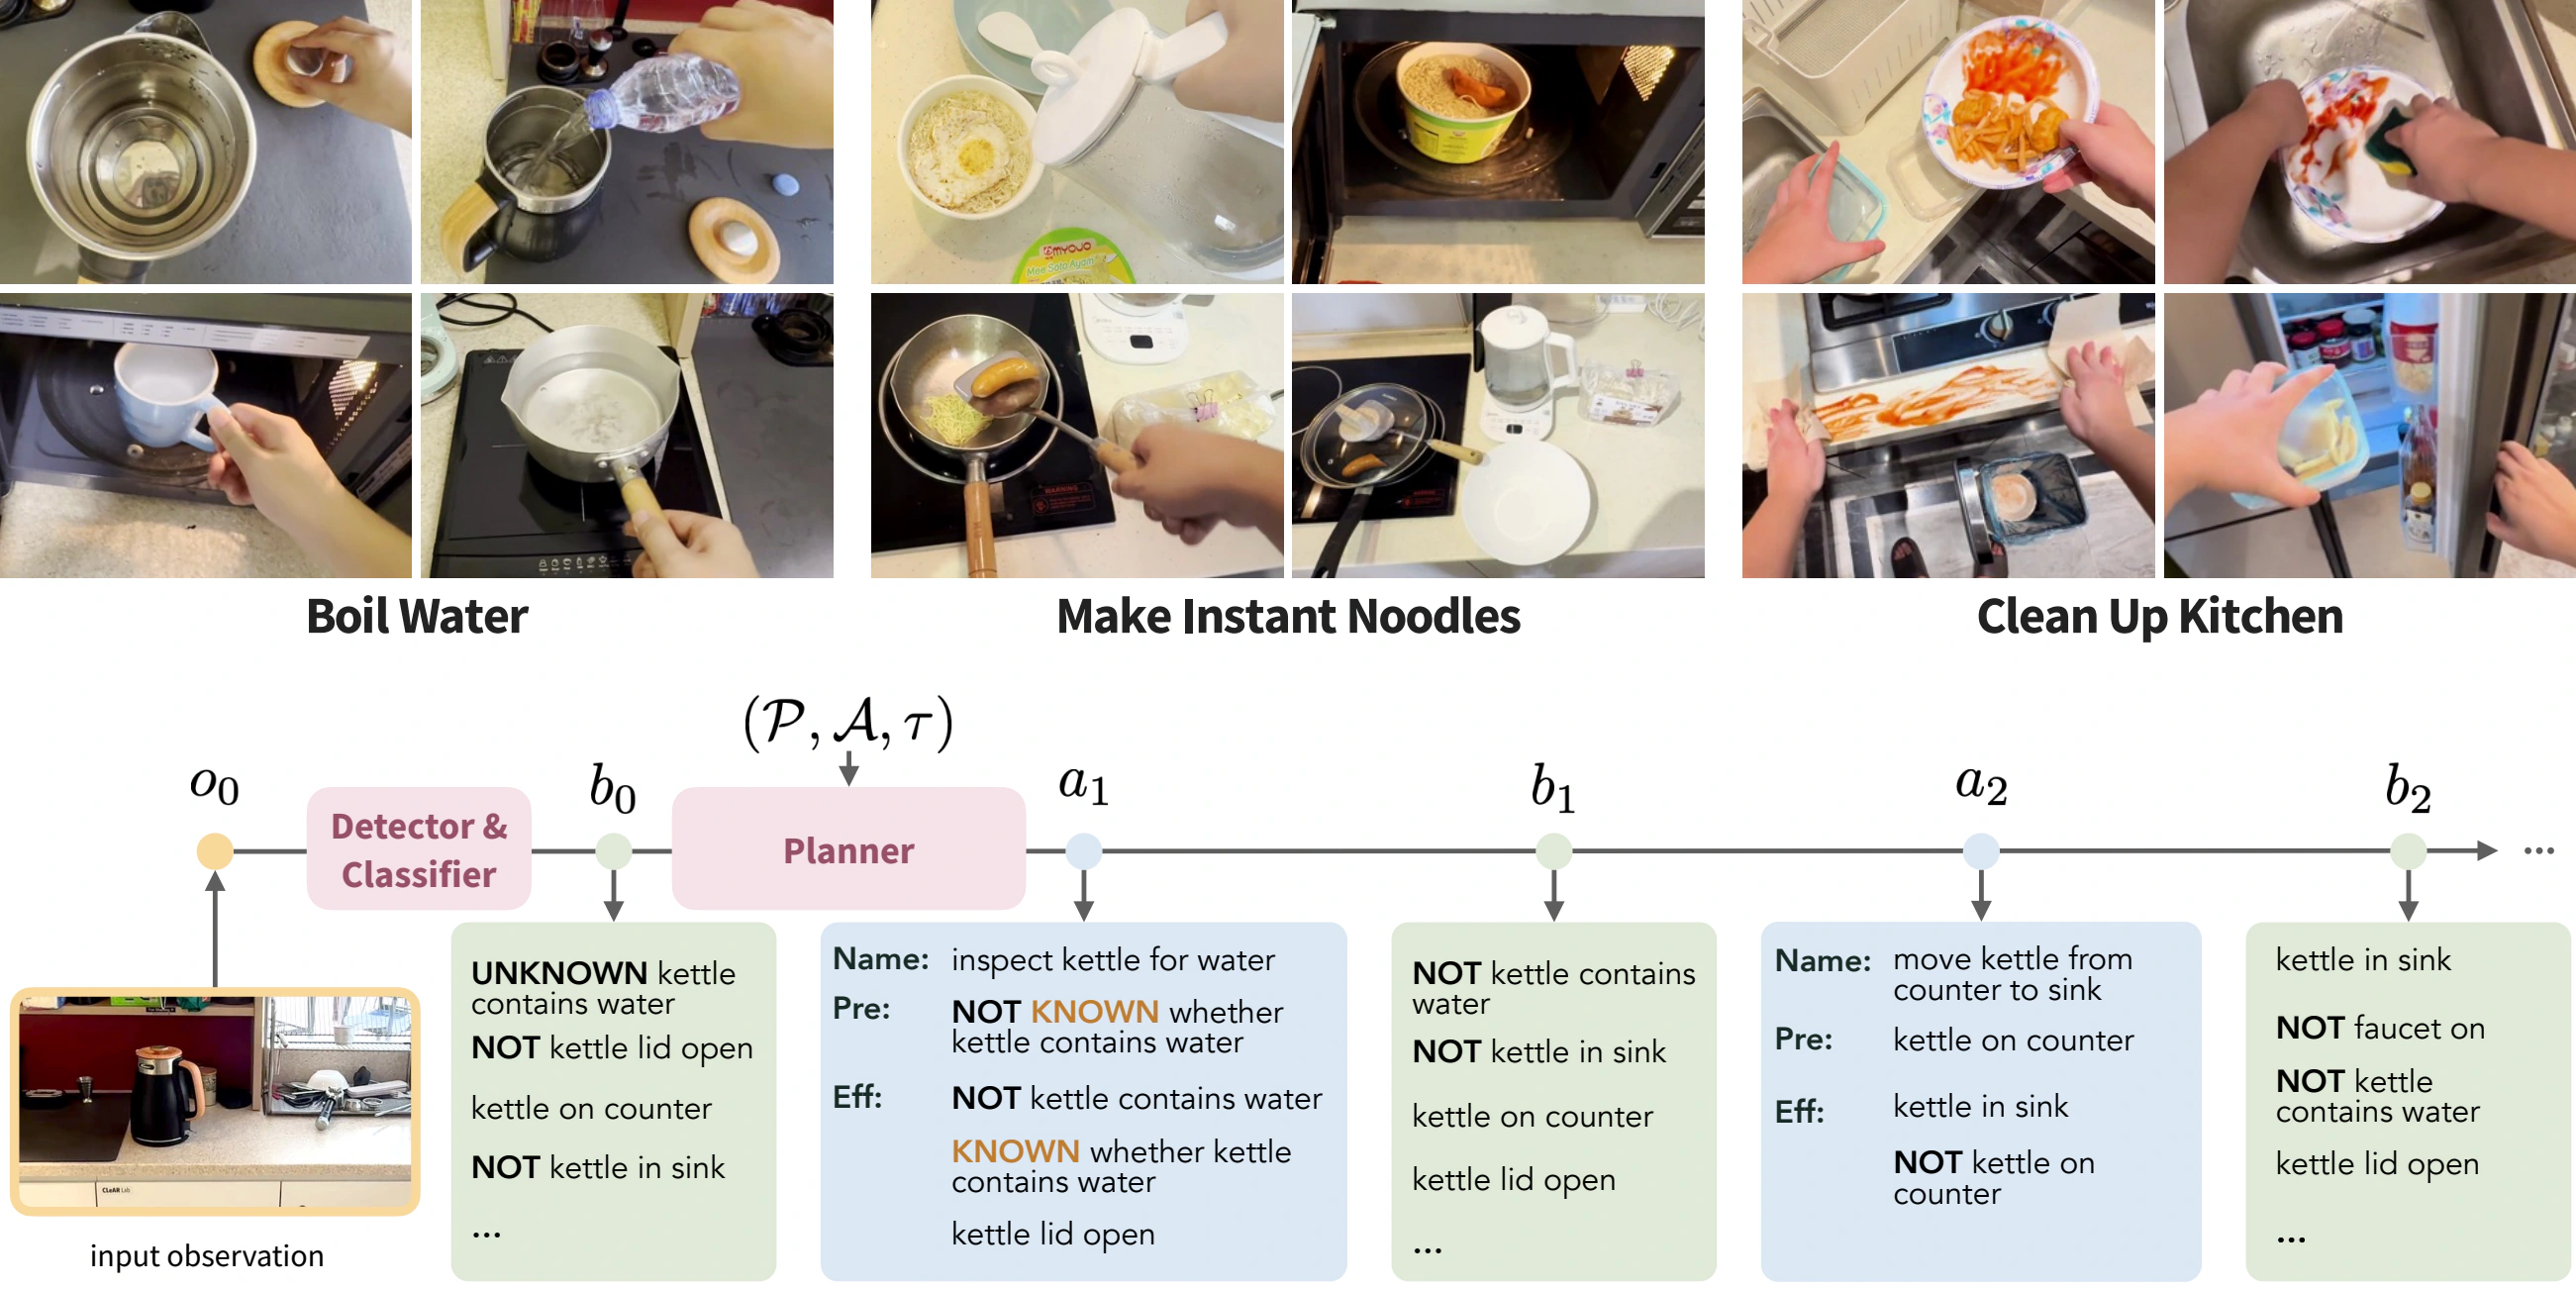
Video frames show Boil Water, Make Instant Noodles, and Clean Up Kitchen. Below, the planner inspects a kettle, updates its belief about the water inside, and moves the empty kettle to the sink.

Learning to Plan with Natural-Language World Models from Human Egocentric Videos

Zhuoran Li, Tasha Kim, Jillian Fisher, Chan Young Park, Yejin Choi, Weiyu Liu†, David Hsu†, Jiajun Wu†

Under Review, 2026

PAW learns a natural-language abstract world model from unlabelled egocentric videos and uses it to reconstruct state–action supervision. The same world model conditions the planner during supervised fine-tuning and inference, enabling planning beyond demonstrated procedures by recombining familiar actions to reach a given goal.
Education

Stanford University

M.S. in Computer Science

Sep 2026 – Present

National University of Singapore

B.Sc. (Honours) in Data Science and Analytics

Highest Distinction

Aug 2019 – Jun 2024

Research Experience

Stanford University & National University of Singapore

Research Assistant · Stanford Vision and Learning Lab & AdaComp

Independently led PAW under the guidance of Prof. Jiajun Wu, Prof. David Hsu, and Prof. Weiyu Liu.

Jun 2025 – Sep 2026

National University of Singapore

Undergraduate Research Assistant · GLOW.AI

Studied language models for planning under uncertainty in my honours thesis with Prof. Bryan Kian Hsiang Low.

Sep 2023 – May 2024

University of Illinois Urbana-Champaign

Undergraduate Research Assistant · RoboPIL

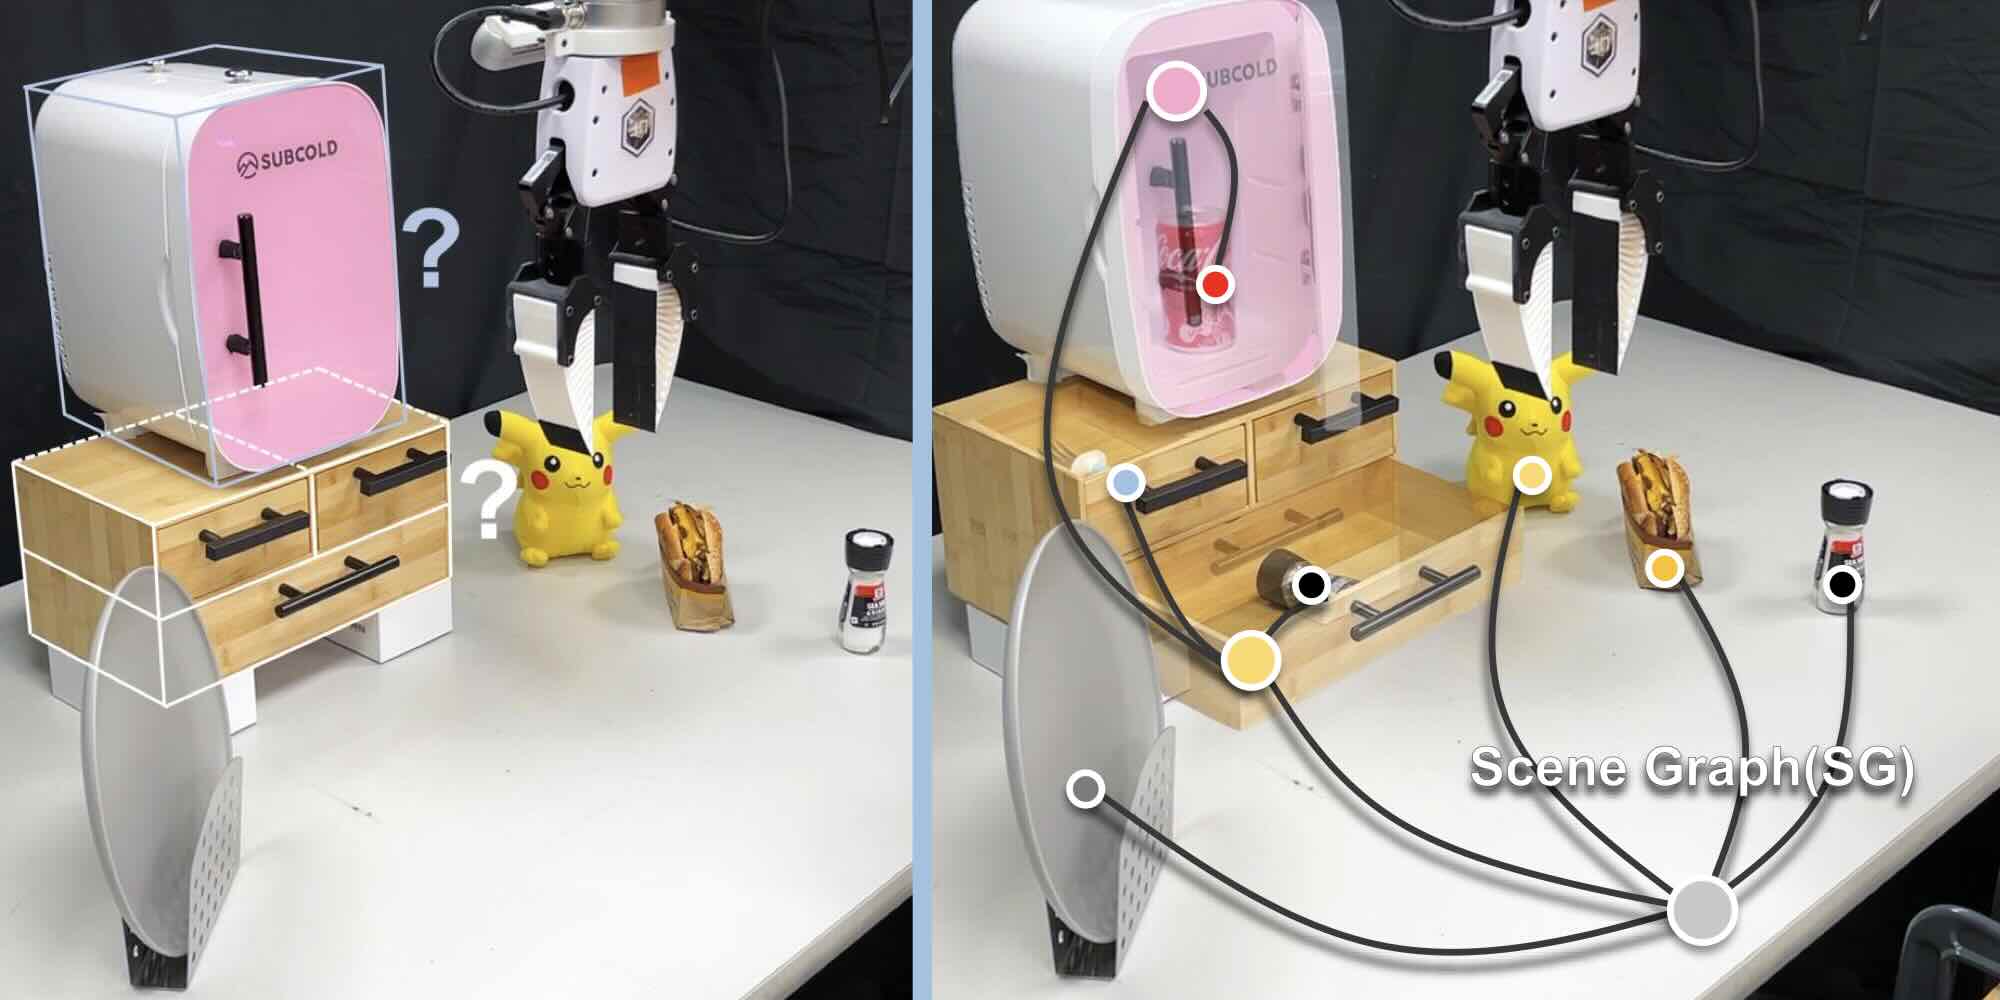
Worked on RoboEXP with Prof. Yunzhu Li.

Oct 2023 – Feb 2024

Stanford University

Undergraduate Visiting Research Intern · Stanford Vision and Learning Lab

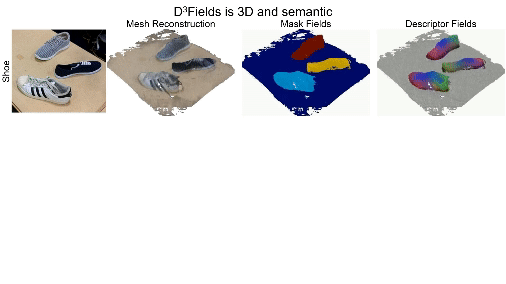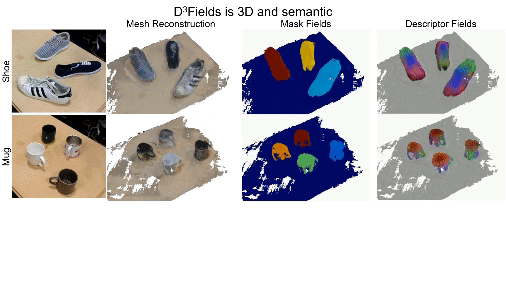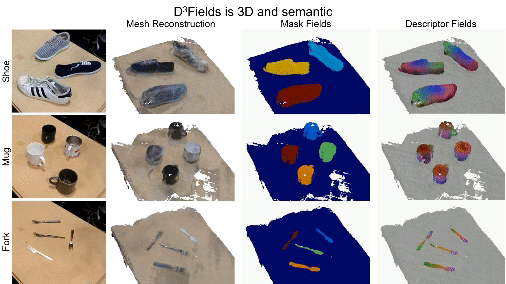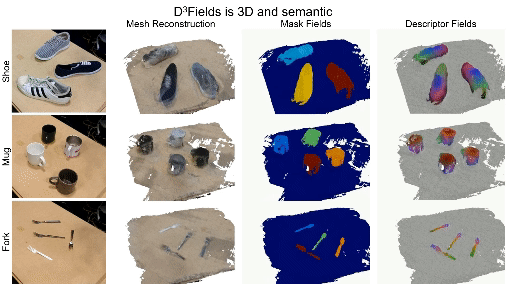
Worked on D³Fields with Prof. Jiajun Wu and Prof. Yunzhu Li.

Apr 2023 – Sep 2023

National University of Singapore

Undergraduate Research Assistant · AdaComp

Worked on long-horizon visual navigation for a Spot robot with Prof. David Hsu.

Jan 2021 – Aug 2021

Teaching